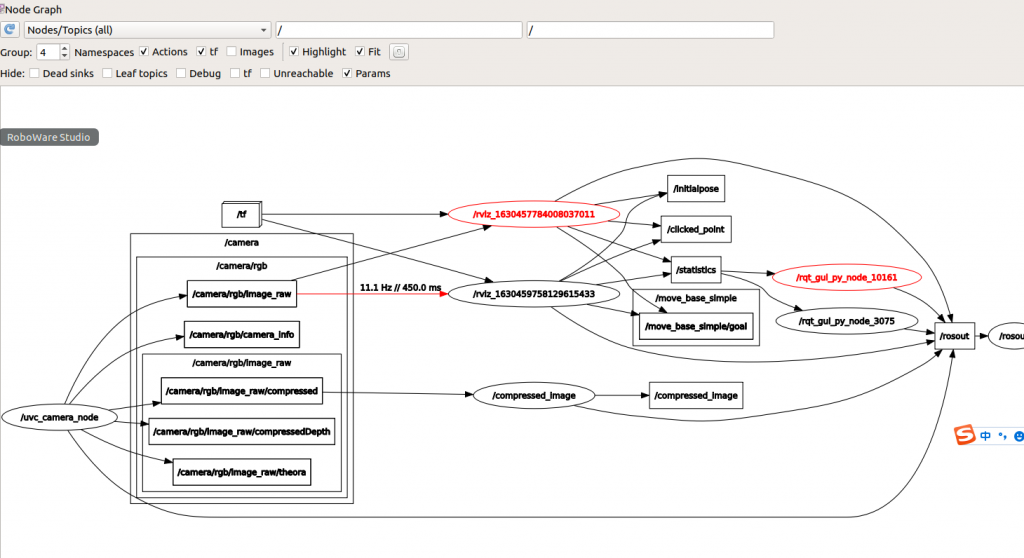
首页 / 博客 / ros-robotics ros-robotics 原文存档 ROS调试方法 2021/09/01 rosrqt_graph调试 rosparam set enable_statistics true rqt_graph 能看到11.1HZ // 450ms